

Healthy Soils
with Robotics?
The Project
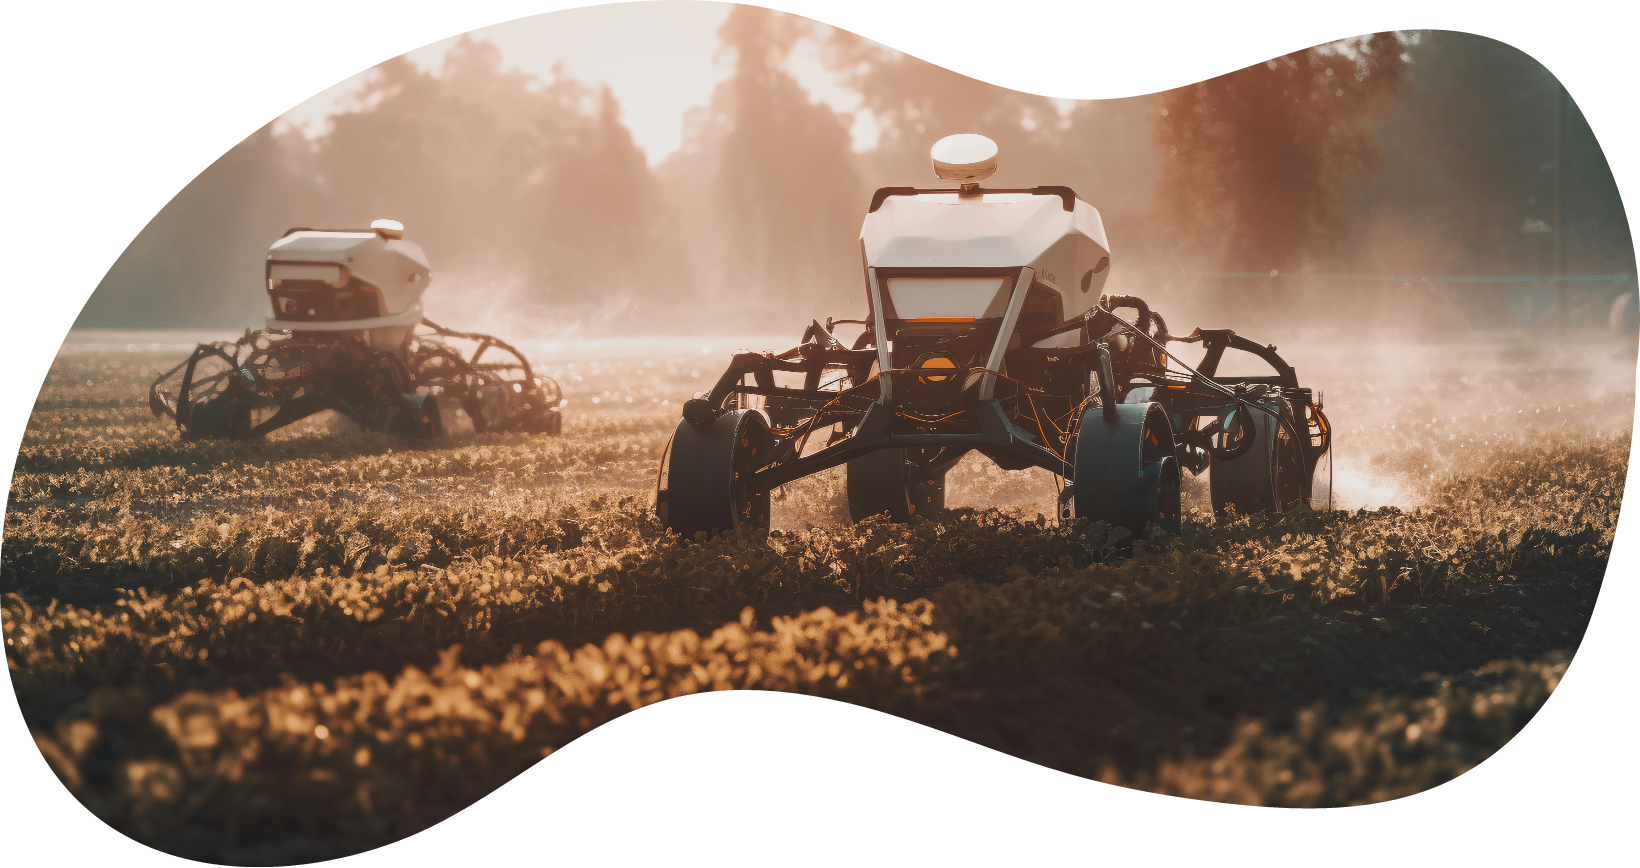
SoilRob investigates the impact of autonomous field robots on soil health in diversified agricultural landscapes. To achieve this, experimental sites with diversified cropping systems are selected both regionally and across Germany, where comprehensive soil parameters are analyzed and compared between conventional farming and diversified systems managed with field robots.
The field robots used in the project are designed for crop-specific interventions and are deployed for seeding, mechanical weed control, or as towing machines. They are characterized by their lighter weight, precise track planning, and extended operational windows in agricultural practice. Based on the findings, the project aims to assess the potential benefits of field robots over conventional agricultural machinery in terms of soil health.
In addition to practical trials, a digital twin of the landscape laboratory will be implemented in a farming simulator. This modeling approach will help predict soil changes and develop recommendations for optimizing the use of field robots.
The ultimate goal of SoilRob is to ensure long-term, sustainable high yields and thus reliable economic viability of autonomously managed diversified cropping systems through improved soil quality.
THE MISSION
A scientifically based investigation into whether and how the use of autonomous field robots in diversified agricultural landscapes can promote soil health and what potential land-use conflicts may arise from their implementation.
SoilRob is a project led by a BMBF-funded junior research group under the leadership of Dr. Kathrin Grahmann at the Leibniz Centre for Agricultural Landscape Research (ZALF) in Müncheberg (Brandenburg), as part of the funding initiative "Young Researchers Exploring the Bioeconomy".
As the scientific coordinator of the patchCROP landscape laboratory, Kathrin Grahmann has many years of experience in experimental and applied agricultural sciences. The extensive scientific, technical, and knowledge transfer activities in SoilRob are driven by Lina Rohlmann, Lukas Thielemann, and Björn Wang.
Starting in October 2024, an additional researcher will join the team to support the implementation of a digital twin of the landscape laboratory.
Events
ZALF, Müncheberg
ZALF, Müncheberg
News
Successful start to the 2026 field season
A new field season has begun, and the SoilRob team has already successfully carried out the first sampling campaigns of the year. We spent several days in the field in Bavaria on the LfL sites, near Göttingen together with the IfZ, and at our two trial sites in Brandenburg.
Back in the field: The second sampling has been completed
The second part of this year’s field season has also been successfully completed. The various methods - including the use of robots for mechanical weed control - have been finished, so we were given the green light to begin sampling
Read more … Back in the field: The second sampling has been completed
Field Campaign Update: LiDAR-Based Soil Surface Roughness Assessment with FarmDroid FD20
As part of our ongoing research into robot–soil interactions, the SoilRob team conducted a field trial on July 1–3, 2026, at ZALF in Müncheberg.
Read more … Field Campaign Update: LiDAR-Based Soil Surface Roughness Assessment with FarmDroid FD20